About Me
Undergraduate researcher at Physical Intelligence Lab, ZJU, advised by Prof. Liangjing Yang and previously by Prof. Hua Chen. Research on embodied AI, focusing on legged locomotion and whole-body loco-manipulation. Recipient of Gold Medal & First Prize at the World Robot Contest Finals (WRCF) and Outstanding Student of Zhejiang University (2025–2026). Maintainer of ENotes, an open notebook on robotics, embodied AI, and university coursework, with research notes and personal logs under More (mostly in Chinese).
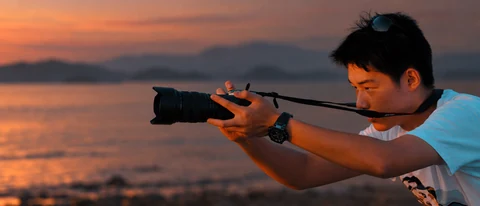
Detailed profile (详细个人介绍)
Hi! I am Chen Jing (Chinese name: 经宸), a sophomore majoring in Mechanical Engineering at the ZJU-UIUC Institute (ZJUI), Zhejiang University. I am an undergraduate research assistant at the Physical Intelligence Lab, advised by Prof. Liangjing Yang and previously by Prof. Hua Chen.
My research focuses on embodied AI, especially legged locomotion and whole-body loco-manipulation. I am also eager to explore other directions that move robotics forward, such as vision-language-action (VLA) models and world models.
Recently, I contributed to a whole-body controller for a bipedal mobile manipulator that tracks a single 6-DoF end-effector target, coordinating arm motion, posture adaptation, and stepping without explicit locomotion commands. My work covers:
- Reward tuning for RL-based whole-body control in Isaac Lab
- Sim2Sim validation of trained policies
- Real-robot deployment on a LimX TRON 1 biped with an ARX L5 arm
I have also worked with UMI-based diffusion policy pipelines.
I come from a robotics-competition and mechanical-design background (WRCF, VEX, ZJU Mechanical Design Competition), which keeps me grounded in how things work on real hardware. I am eager to bridge the gap between simulation and reality to enable robots with more agile and dexterous behaviors.
Hi!我是经宸 (English name: Chen Jing),浙江大学–伊利诺伊大学厄巴纳-香槟校区联合学院(ZJUI)机械工程专业大二学生。目前是 Physical Intelligence Lab 的本科生科研助理,师从杨量景教授,此前师从谌骅教授。
我的研究方向是具身智能,尤其关注足式运动与全身移动操作(loco-manipulation)。同时,我也乐于探索其他推动机器人发展的方向,例如视觉-语言-动作模型(VLA)与世界模型。
近期,我参与了一项双足移动操作机器人的全身控制器工作:仅给定一个 6-DoF 末端执行器目标,控制器即可协调手臂运动、姿态调整与迈步,无需显式的运动指令。我主要负责:
- 在 Isaac Lab 中为基于强化学习的全身控制进行奖励函数调参
- 对训练得到的策略进行 Sim2Sim 验证
- 在搭载 ARX L5 机械臂的 LimX TRON 1 双足机器人上进行真机部署
此外,我还接触过基于 UMI 的 diffusion policy 流程。
我有机器人竞赛与机械设计的背景(WRCF、VEX、浙江大学机械设计竞赛),这让我始终关注真实硬件上的实际表现。我希望弥合仿真与现实之间的差距,让机器人具备更敏捷、更灵巧的行为。
Recent News
- Awarded the Zhejiang Provincial Government Scholarship!
- Honored as Outstanding Student, Pacesetter in Academic Excellence, and Pacesetter in International Exchange by Zhejiang University!
- 🎉Our short paper was accepted for a 2-minute spotlight presentation at the MoMA.v5 Workshop at IROS 2026!
- Released EdwinOS 2.1.2 on July 13, 2026, further refining the GitHub-inspired experience for the personal website!
Education
-
 Sep. 2025 — Jul. 2029 (Expected)Hangzhou
Selected Experiences
Physical Intelligence Lab, ZJU
Research Assistant — Whole-body control · Reinforcement learning · Reward tuning · Sim2Sim & Sim2Real
Jun. 2026 — Present
Publications
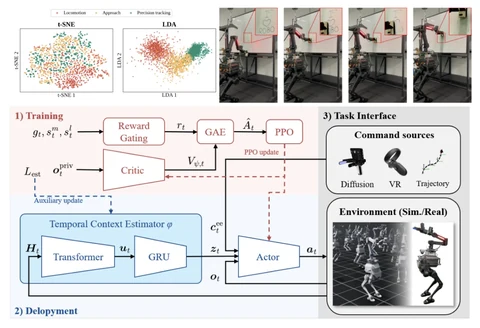
Learning Holistic Whole-Body Loco-Manipulation with a Bipedal Mobile Manipulator
Under Review
* Equal contribution · † Corresponding author
Workshop Contributions & Presentations
MoMA.v5 Workshop IEEE/RSJ IROS 2026
Learning Holistic Whole-Body Loco-Manipulation with a Bipedal Mobile Manipulator
Our short paper was accepted for a poster session and a 2-minute spotlight presentation.
Honors & Awards
- 11/2026Zhejiang Provincial Government Scholarship · CNY 6,000
- 10/2026Outstanding Student · Zhejiang University
- 10/2026Pacesetter in Academic Excellence · Zhejiang University, CNY 10,000
- 10/2026Pacesetter in International Exchange · Zhejiang University
- 04/2026Third Prize · 31st Zhejiang University Mechanical Design Competition
- 01/2024Gold Medal & First Prize · World Robot Contest Finals (WRCF)
- 08/2023Second Prize · National VEX Robotics Elite Competition (Hosted by SJTU)